Reliable language-guided robot navigation
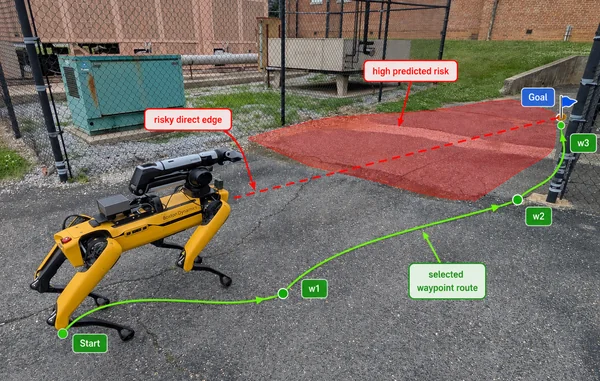
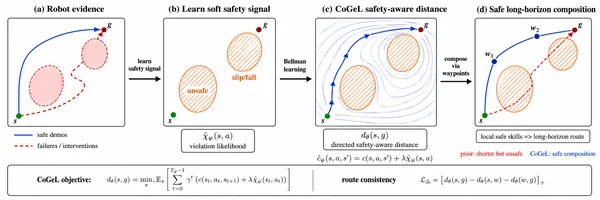
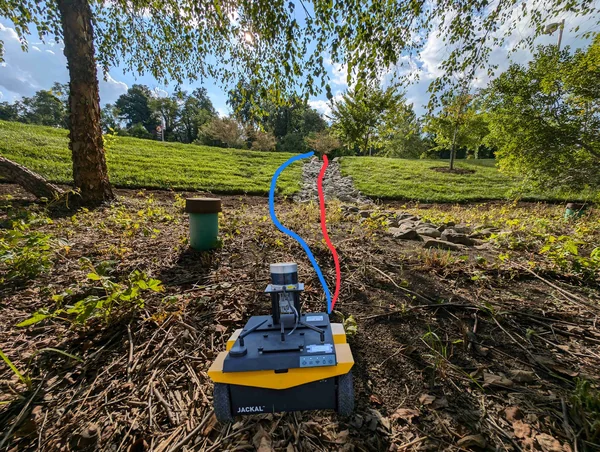
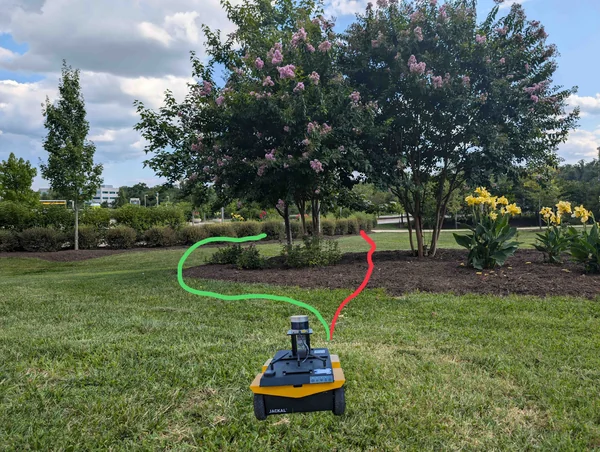
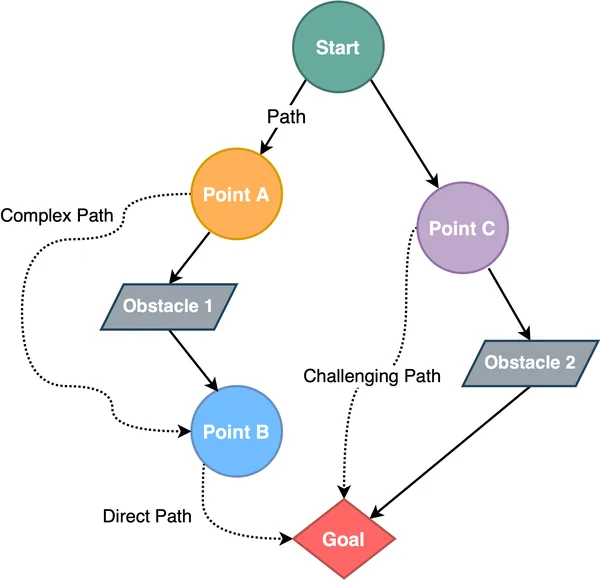
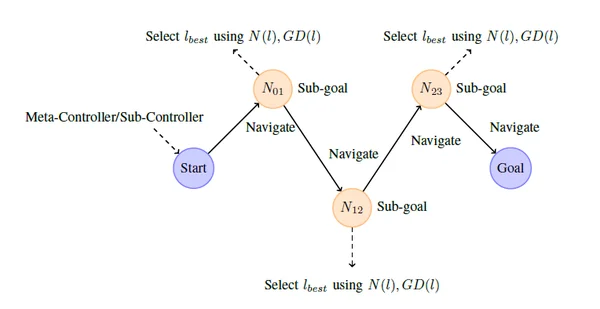
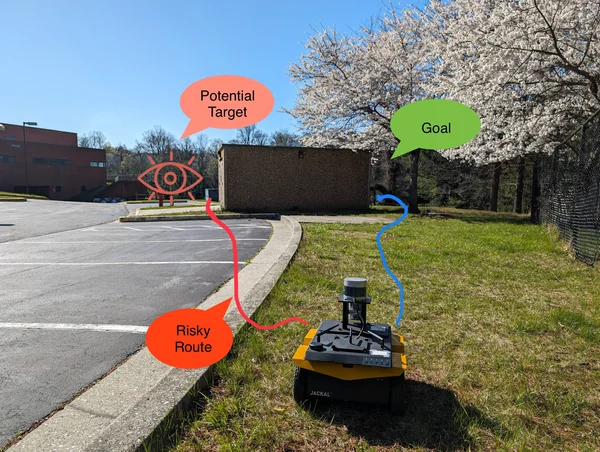
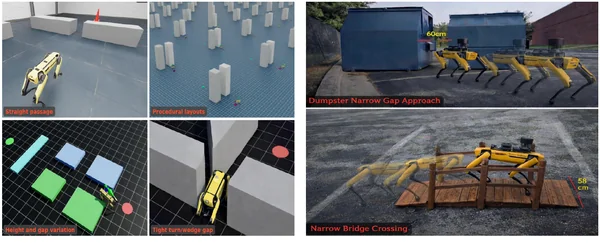
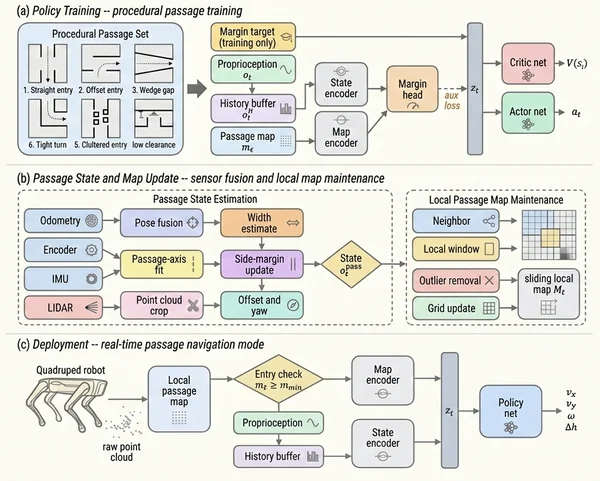
Current research explores language-guided navigation and narrow-gap traversal under uncertainty. Learned risk estimates guide route selection and recovery, while control based on available clearance adjusts body alignment through tight passages. The goal is to connect task understanding with the physical constraints that determine whether a route can be completed reliably.