CoGeL · CoRL 2026
CoGeL: Constraint-to-Geometry Learning from Demonstrations and Failures for Safe Long-Horizon Robot Navigation
Learning a directed navigation distance from demonstrations, failures, and interventions to guide safer decisions over long horizons.
Paper and code resources will be added when available.
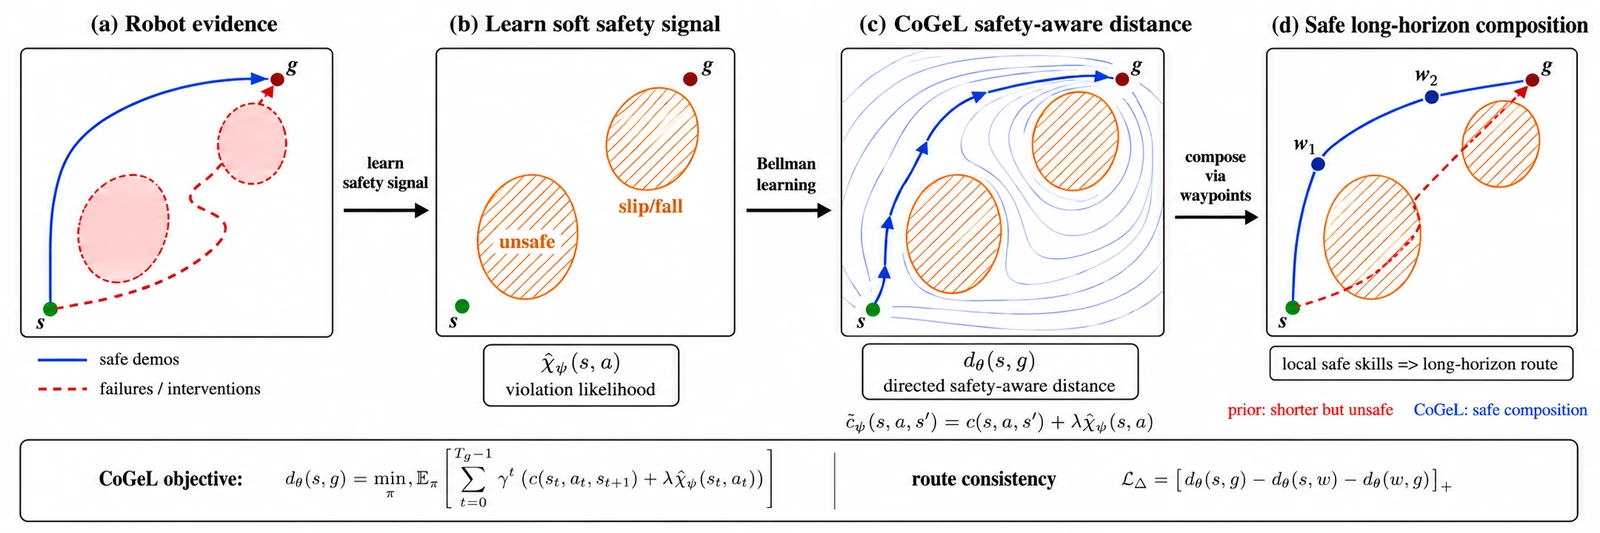
Overview
Local experiences can reveal a hazard without explaining how to plan around it over a long route. CoGeL studies how that safety evidence can shape the representation used for navigation.
The framework converts demonstrations, failures, and interventions into a directed navigation distance. The resulting geometry helps the robot account for local constraints when choosing a route toward a distant goal.