TopoNav · IROS 2024
TopoNav: Topological Navigation for Efficient Exploration in Sparse Reward Environments
Combining topological maps, hierarchical reinforcement learning, and intrinsic rewards for exploration with sparse feedback.
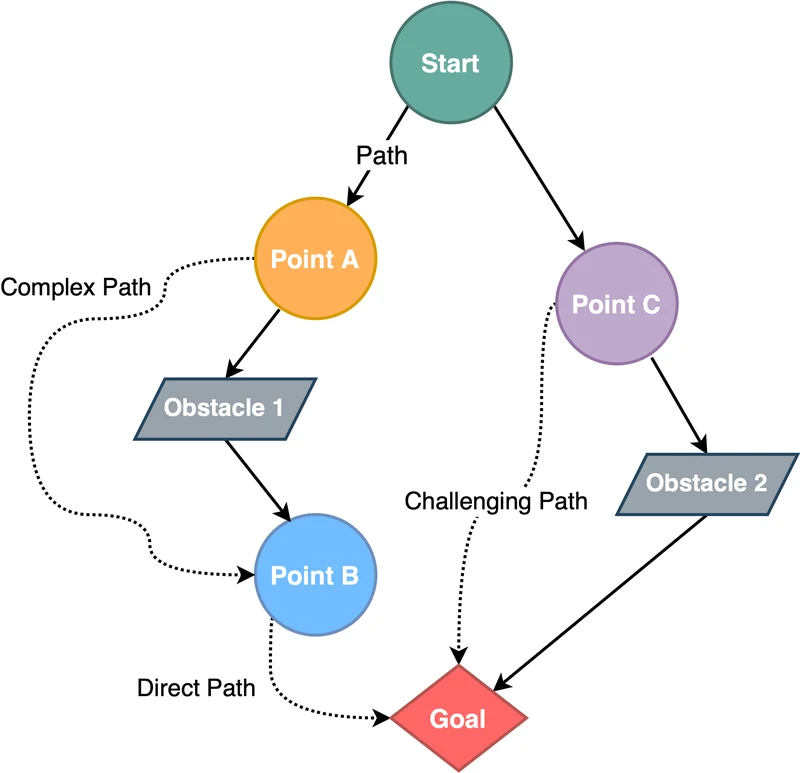
Overview
When rewards are sparse, an exploring robot must choose useful intermediate objectives before it can reach its final goal.
TopoNav builds active topological maps and combines them with hierarchical reinforcement learning and intrinsic rewards to guide exploration in unfamiliar environments.