From learning to physical systems

Robots I've worked with

My work spans humanoid, quadruped, and wheeled robots, connecting reinforcement learning and simulation with the challenges of real-world autonomy.

Humanoids

Quadrupeds

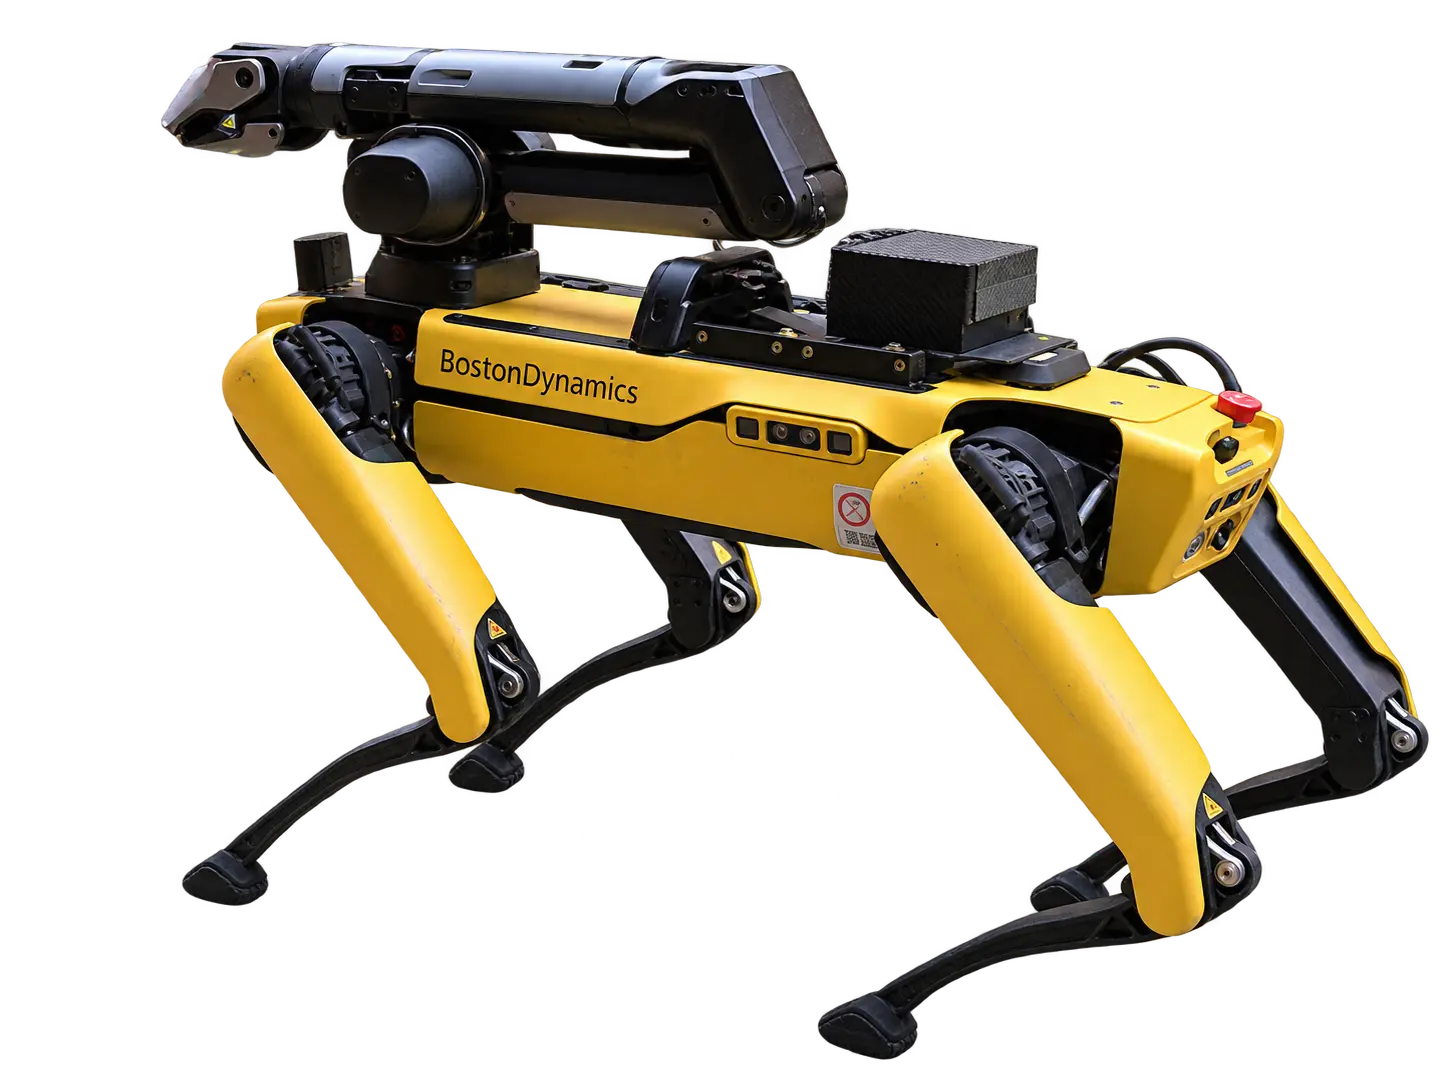
Boston Dynamics Spot quadruped with a folded robotic arm and mounted sensor, isolated on a transparent background

Quadruped

Boston Dynamics Spot

Legged navigation and perception

A four-legged robot that can move through cluttered spaces, climb stairs, and traverse uneven ground. Its payload interfaces support additional sensing and onboard computing for mapping and navigation research.

Platform details
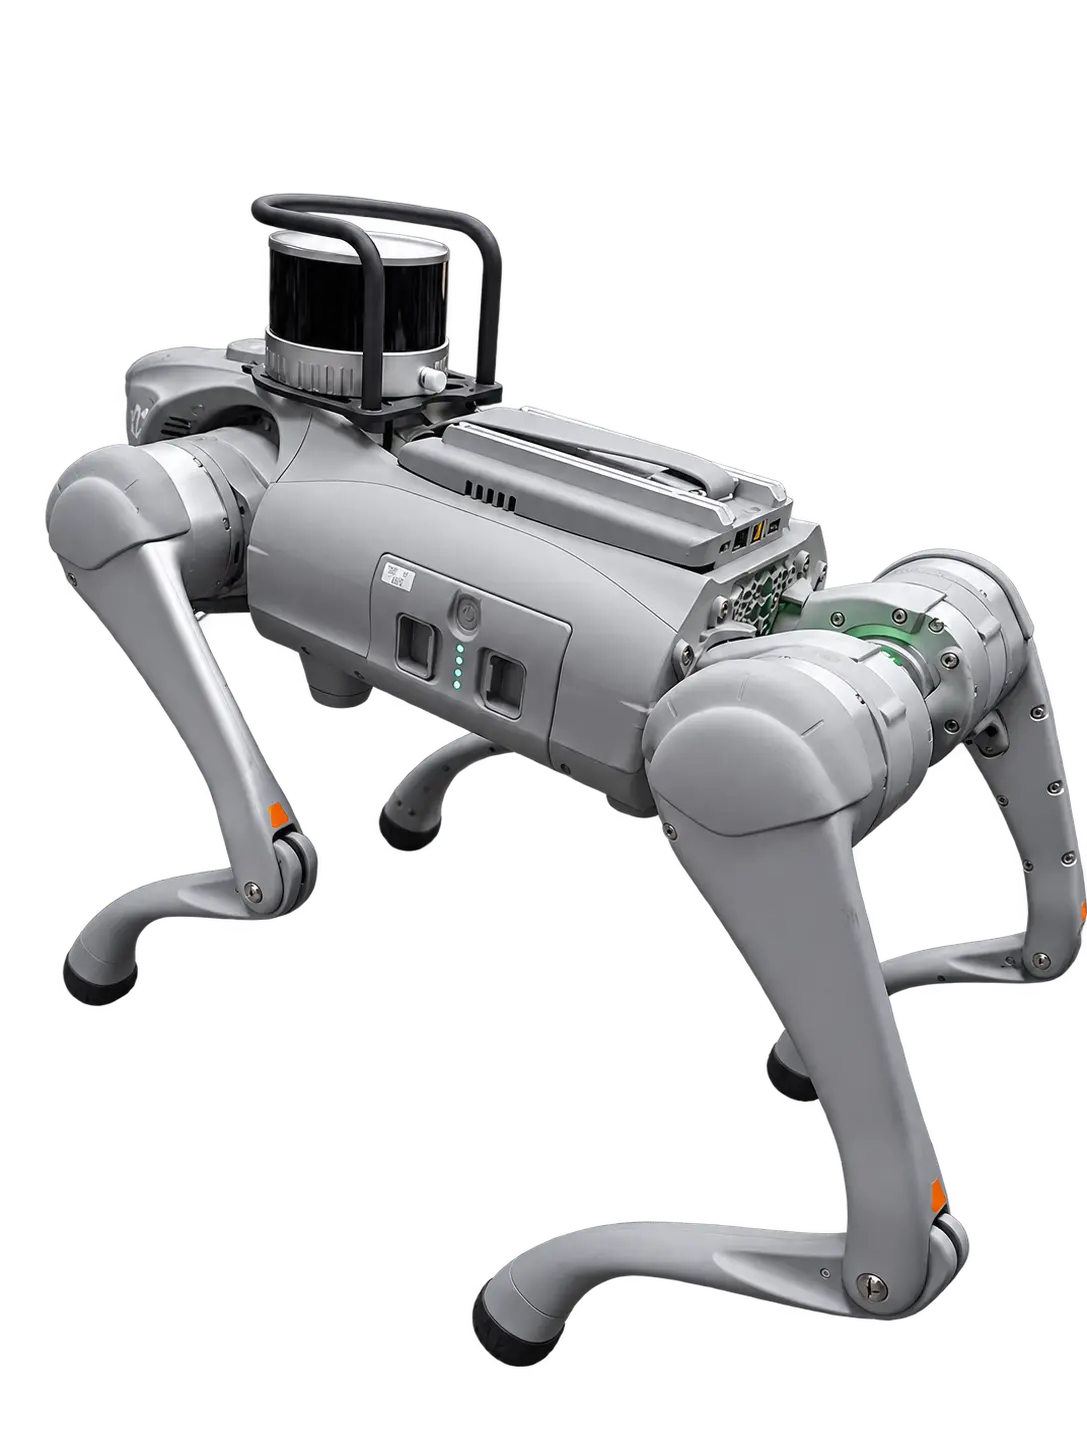
Gray Unitree Go2 quadruped with mounted lidar and onboard computer, isolated on a transparent background

Quadruped

Unitree Go2

Compact, agile legged mobility

A lightweight quadruped with onboard perception and developer interfaces for locomotion and autonomy research. The EDU platform supports experiments with robot control, mapping, and navigation.

Platform details
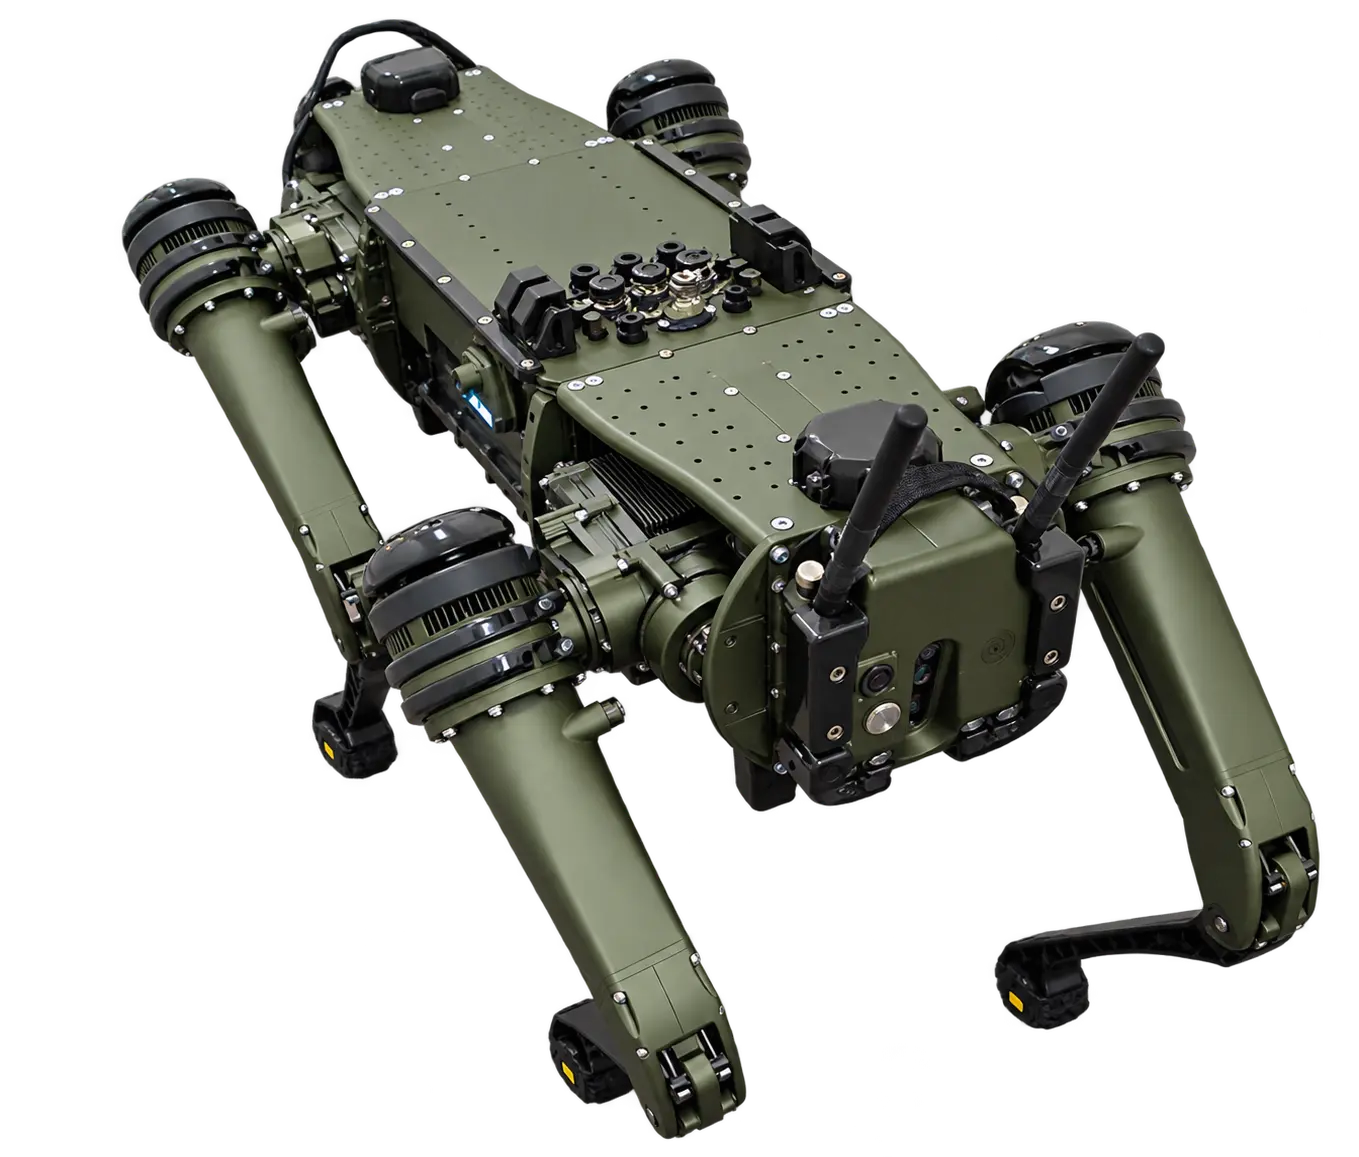
Olive green Ghost Robotics Vision 60 quadruped with front sensors and antennas, isolated on a transparent background

Quadruped

Ghost Robotics Vision 60

Mobility in challenging terrain

A rugged quadruped built for outdoor operation and uneven terrain. Its modular payload mounts accommodate sensors and computing hardware for perception and autonomous navigation.

Platform details

Wheeled robots

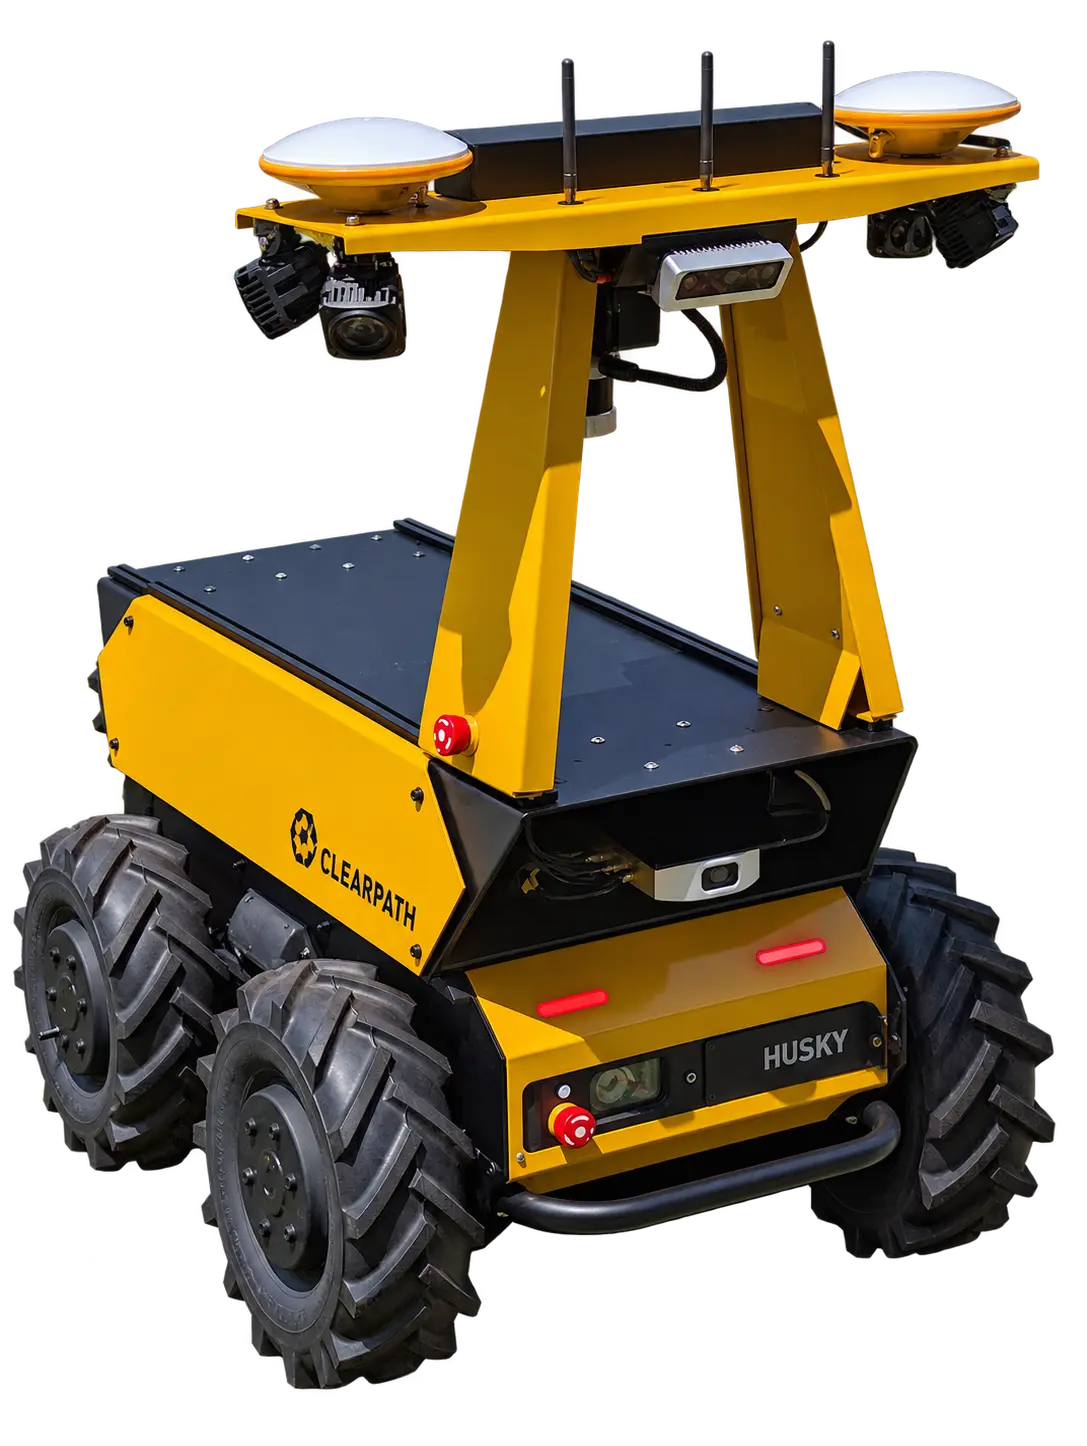
Yellow and black Clearpath Husky with cameras, antennas, and GPS receivers on a raised sensor frame, isolated on a transparent background

Wheeled

Clearpath Husky

Outdoor autonomy and field robotics

A four-wheeled research platform for outdoor robotics. Its larger chassis carries sensing and computing payloads, making it useful for mapping, terrain perception, and navigation experiments.

Platform details
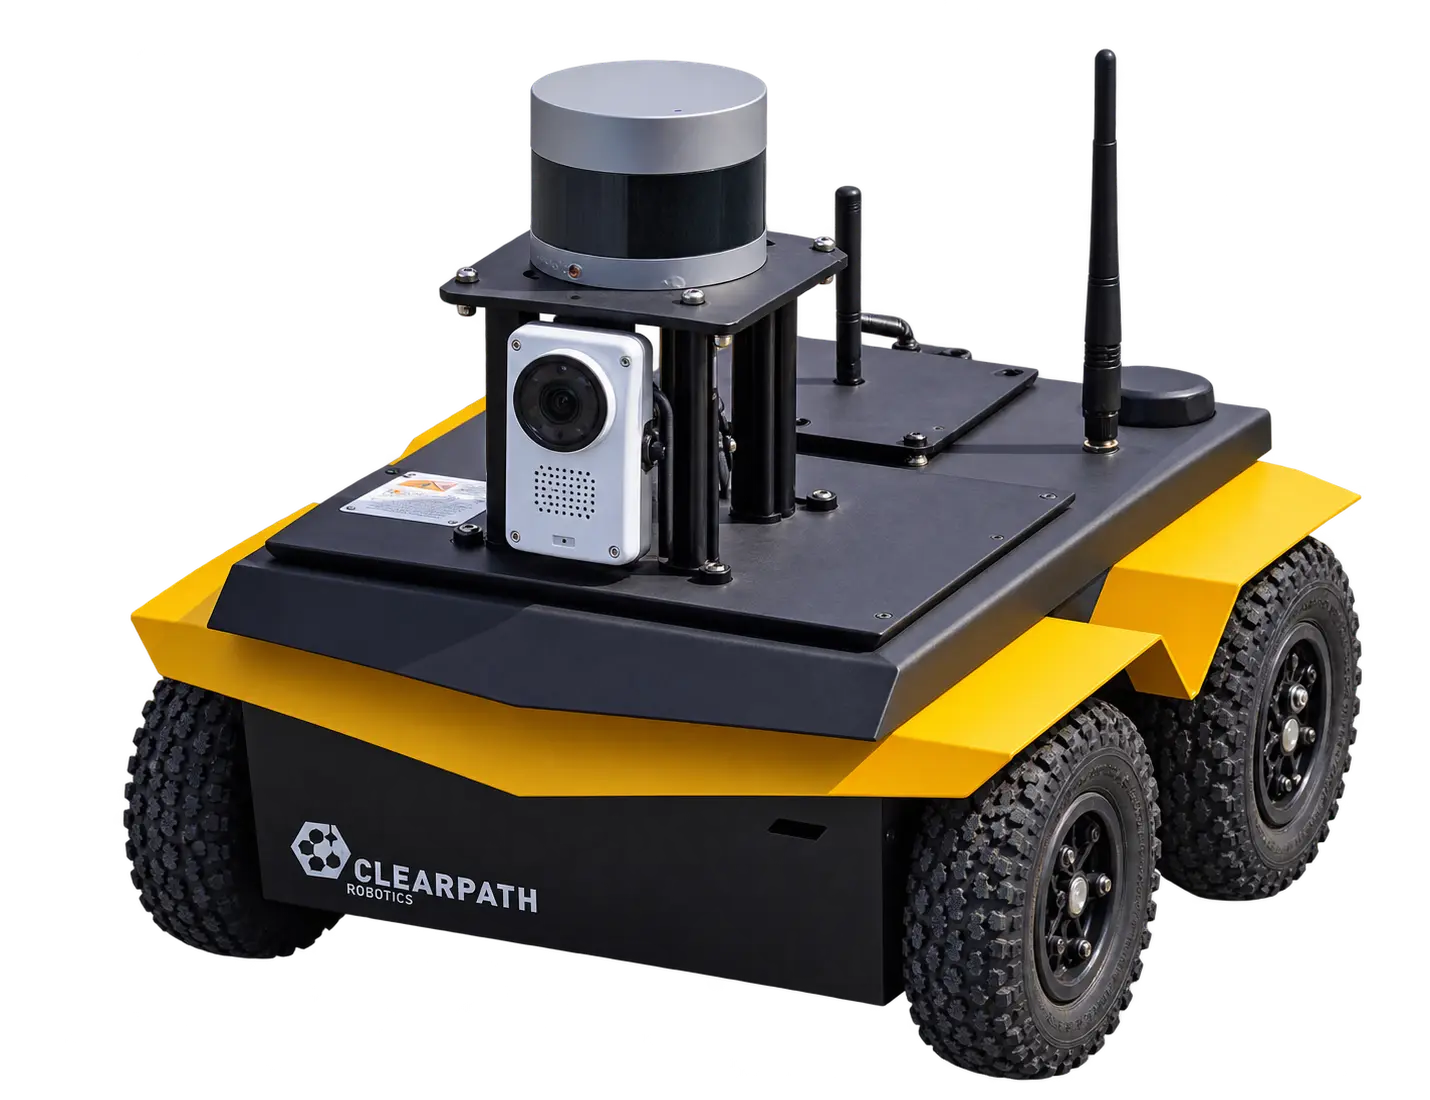
Yellow and black Clearpath Jackal with mounted lidar, camera, and antennas, isolated on a transparent background

Wheeled

Clearpath Jackal

Compact mobile-robot navigation

A compact four-wheeled robot for indoor and outdoor research. Its small footprint and integrated computing make it a practical platform for testing perception, planning, and navigation in constrained spaces.

Platform details
Official ROBOTIS image showing the TurtleBot3 Burger and Waffle Pi platforms

Wheeled

TurtleBot3

ROS prototyping and indoor autonomy

A small, modular ROS-based mobile robot for research and prototyping. Its accessible hardware and software ecosystem support experiments in mapping, localization, and indoor navigation.

Platform details
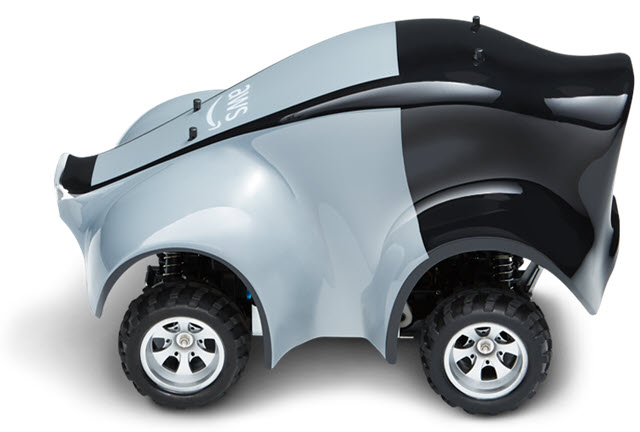
Amazon DeepRacer autonomous racing car in an official AWS product image

Wheeled

Amazon DeepRacer

Early PhD work · 2021

A 1/18-scale autonomous racing car for hands-on reinforcement learning, with driving policies trained in simulation and deployed on the vehicle. I used DeepRacer in 2021, during the early stages of my PhD.

Platform details