GapNav · Under review
GapNav: Margin-Aware Gap Entry and Traversal Control for Legged Robots
Using available clearance to guide a legged robot into and through passages near its physical limits.
Paper and code resources will be added when available.
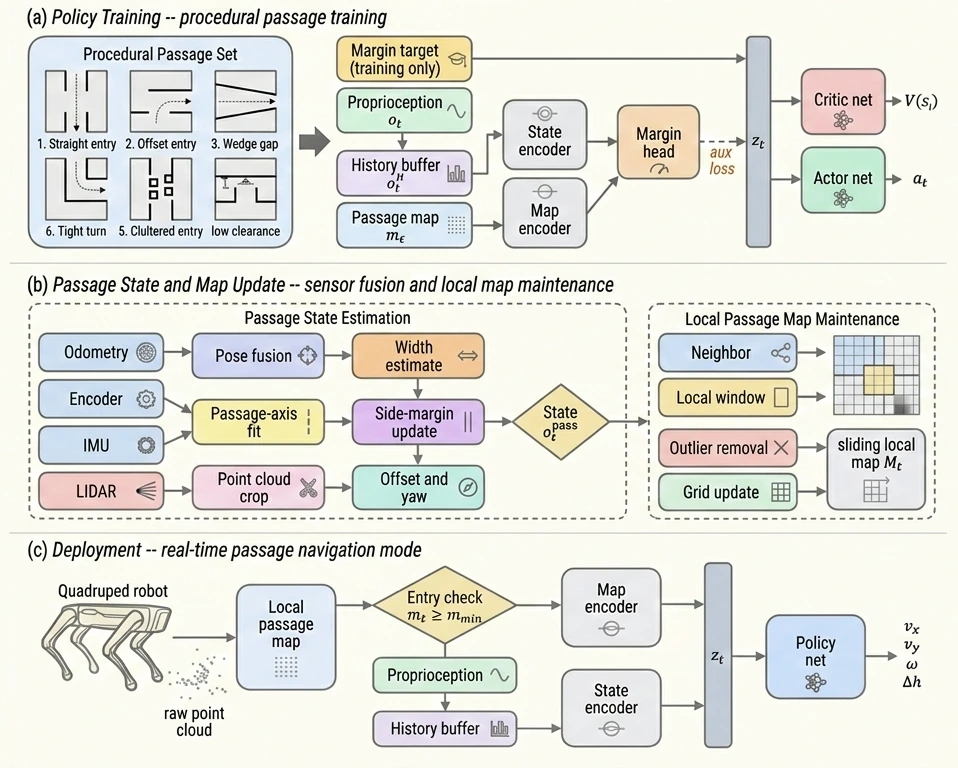
Overview
A robot can clear the entrance to a passage and still collide during the crossing. Small changes in yaw, lateral position, and body height can consume the remaining clearance.
GapNav estimates the available side margin and adjusts motion throughout the passage. Its controller treats entry and traversal as a connected task, with explicit attention to the robot's physical clearance.