SynchroSim · IEEE DCOSS 2022
SynchroSim: An Integrated Co-simulation Middleware for Heterogeneous Multi-robot System
Co-simulation middleware for communication and synchronization across heterogeneous robot systems.
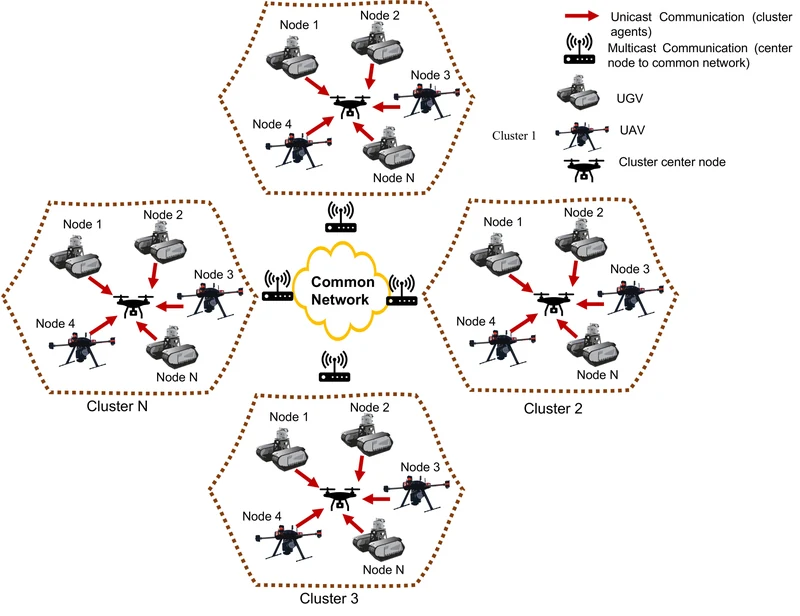
Overview
Experiments with heterogeneous robots often span different simulators and software interfaces.
SynchroSim provides middleware for coordinating those systems, supporting communication and synchronization in multi-robot co-simulation.