FiRL · ICML 2026
Learning Anisotropic Value Geometry with Finsler Reinforcement Learning
Learning value geometry that accounts for direction-dependent motion costs and rare, high-cost failures.
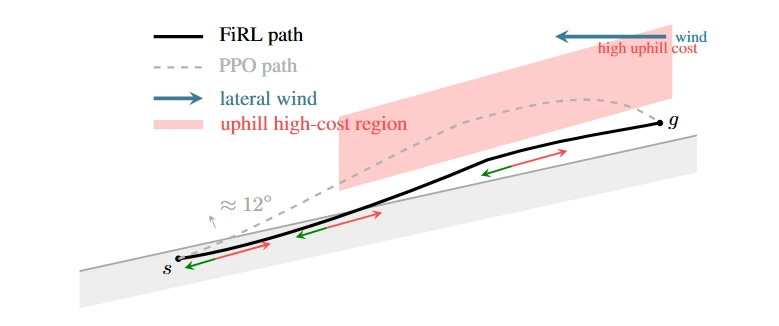
Overview
Moving between the same two states can have different physical costs in opposite directions. Uphill travel, lateral slip, and terrain hazards make this asymmetry important for robot locomotion.
FiRL combines a direction-dependent Finsler-style cost with a tail-risk objective. The policy considers both the effort of a motion and the possibility of unusually costly outcomes.