CoverNav · ACSOS 2023
CoverNav: Cover Following Navigation Planning in Unstructured Outdoor Environment with Deep Reinforcement Learning
Learning navigation behavior that follows available cover in unstructured outdoor environments.
Overview
Outdoor navigation requires a robot to reason about obstacles, traversability, and the structure of its surroundings.
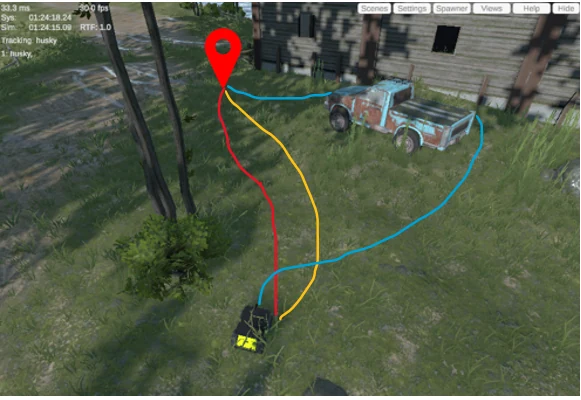
CoverNav uses deep reinforcement learning to plan routes that follow cover while progressing toward the navigation goal.