QuasiNav · ICRA 2025
QuasiNav: Asymmetric Cost-Aware Navigation Planning with Constrained Quasimetric Reinforcement Learning
Planning robot routes with asymmetric costs and constraints using quasimetric reinforcement learning.
Overview
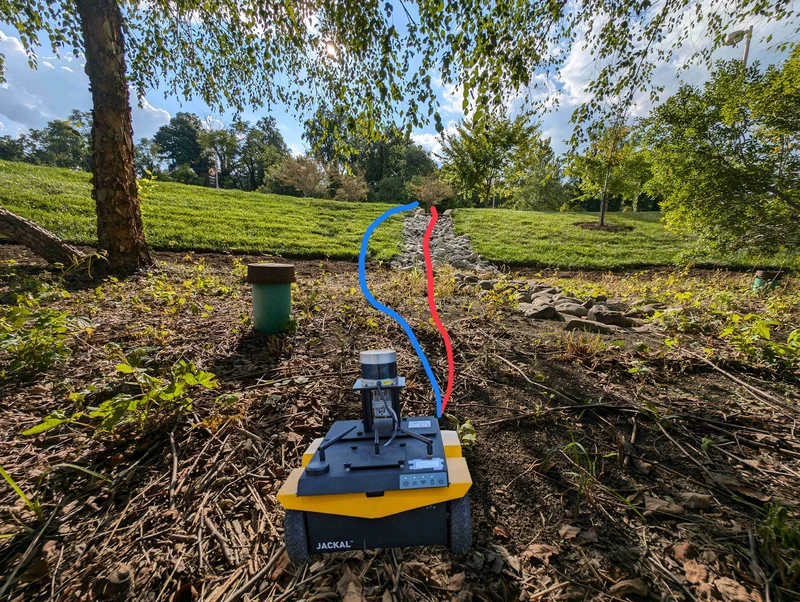
Distance alone does not describe the difficulty of traveling through an uneven environment. A route can be feasible in one direction and expensive or risky in the other.
QuasiNav uses constrained quasimetric reinforcement learning to represent these asymmetric traversal costs and inform navigation planning.