SERN · ICCCN 2026
SERN: Bandwidth-Adaptive Cross-Reality Synchronization for Simulation-Enhanced Robot Navigation
Connecting physical and virtual robots through bandwidth-adaptive synchronization for collaborative navigation.
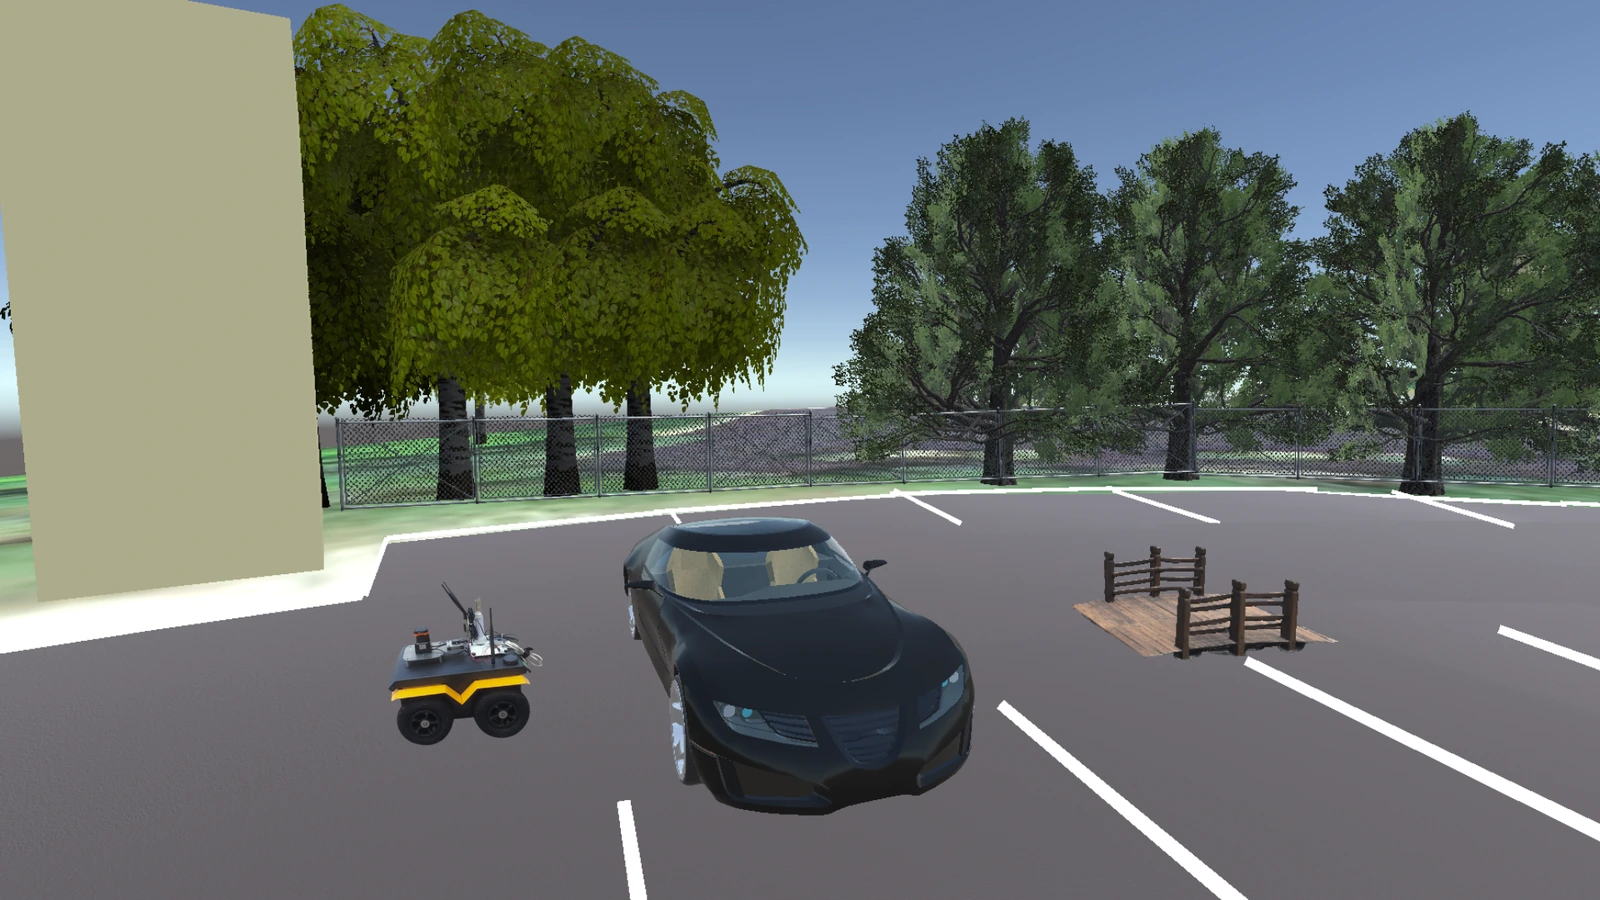
Overview
Simulation can support robot experiments only when the virtual and physical systems remain meaningfully aligned. Communication limits, latency, and changing sensor data make this difficult in distributed robot systems.
SERN connects ROS-based robots with AuroraXR and Unity environments. The work examines synchronization and data exchange between physical and virtual agents for multi-robot navigation.
The linked arXiv version uses the earlier title, “SERN: Simulation-Enhanced Realistic Navigation for Multi-Agent Robotic Systems in Contested Environments.”