EnCoMP · ACSOS 2024
EnCoMP: Enhanced Covert Maneuver Planning with Adaptive Target-Aware Visibility Estimation using Offline Reinforcement Learning
Using target-aware visibility estimates and offline reinforcement learning to plan cover-aware maneuvers.
Overview
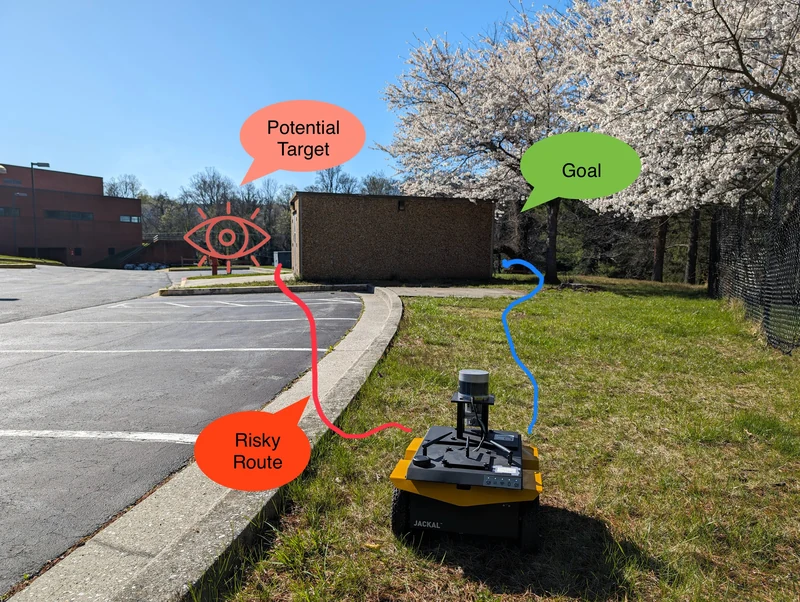
A robot navigating near obstacles may need to consider how visible its route is from another location, as well as whether the route is traversable.
EnCoMP incorporates adaptive, target-aware visibility estimation into offline reinforcement learning for maneuver planning.