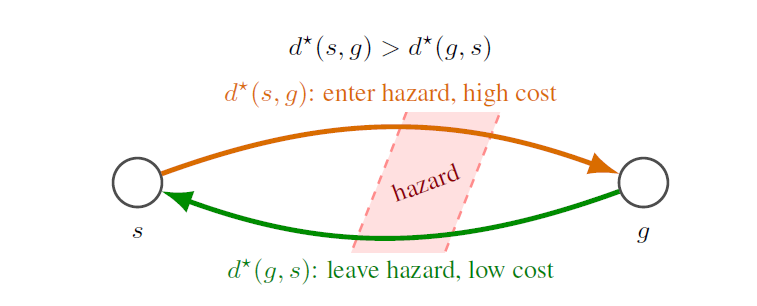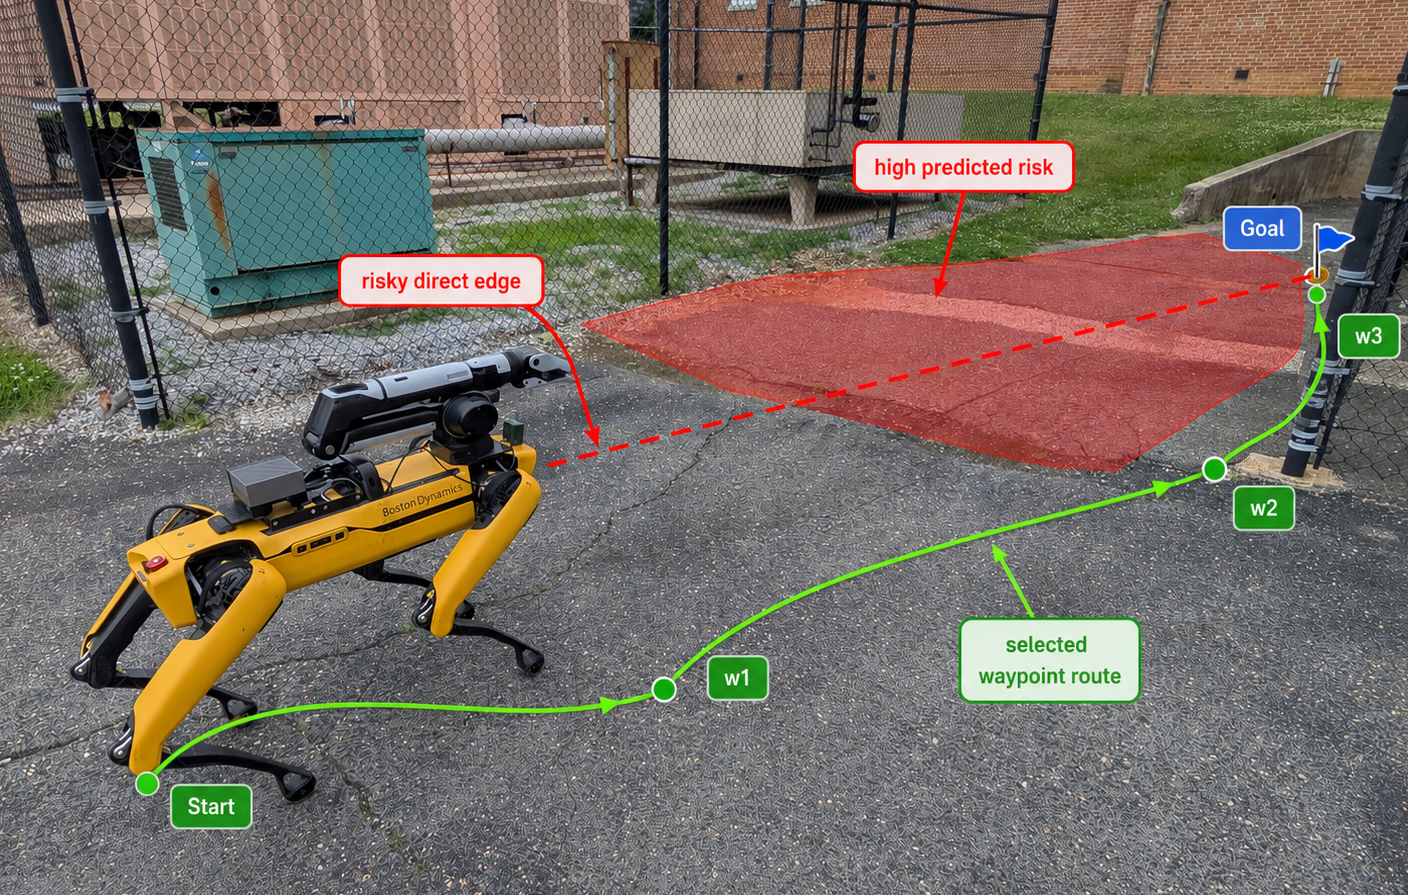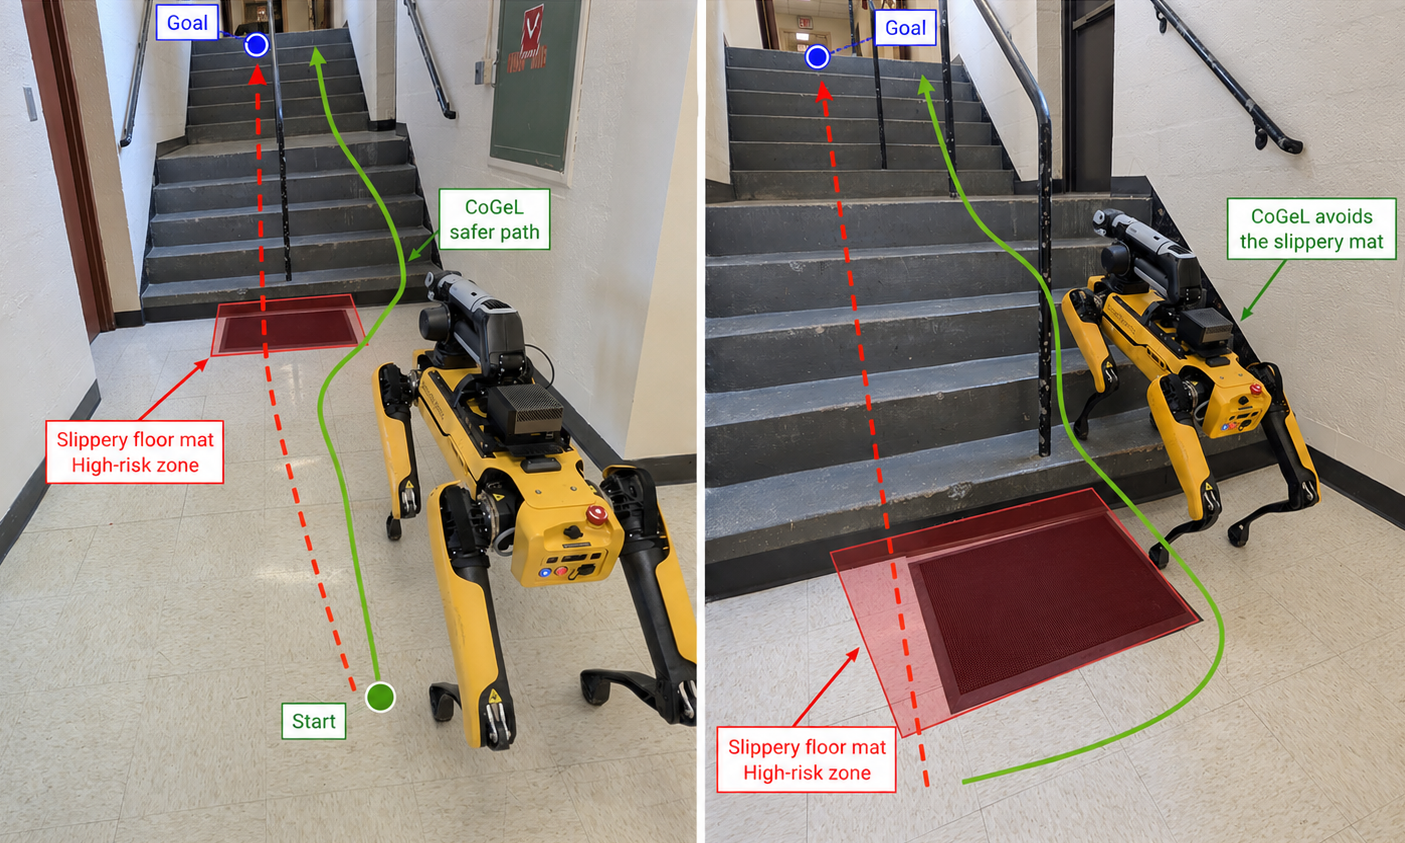
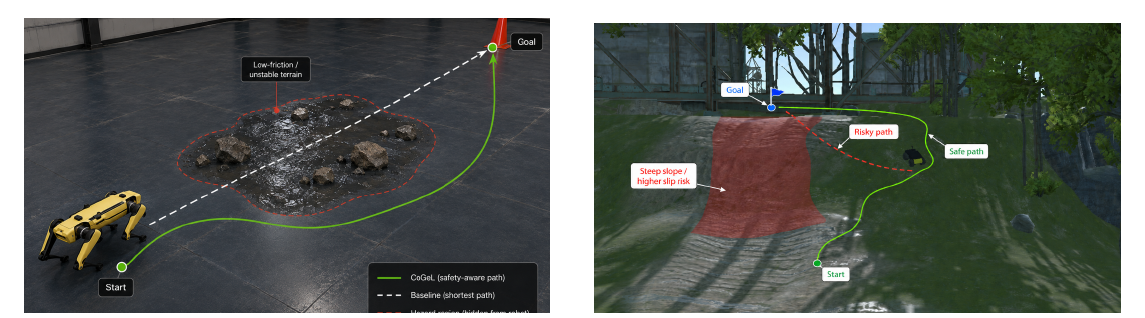
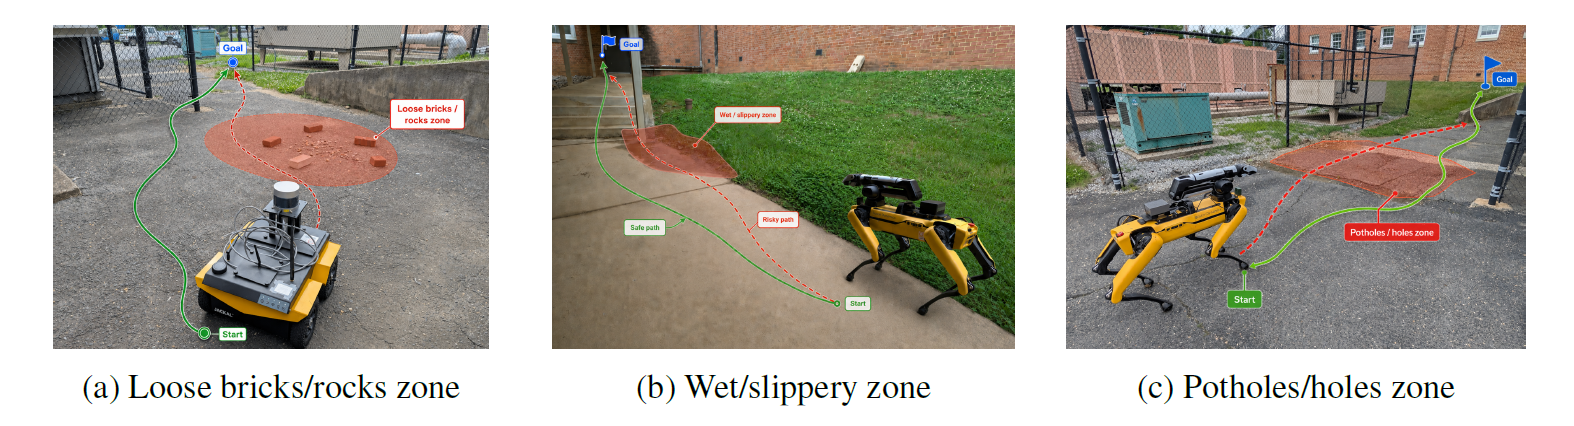
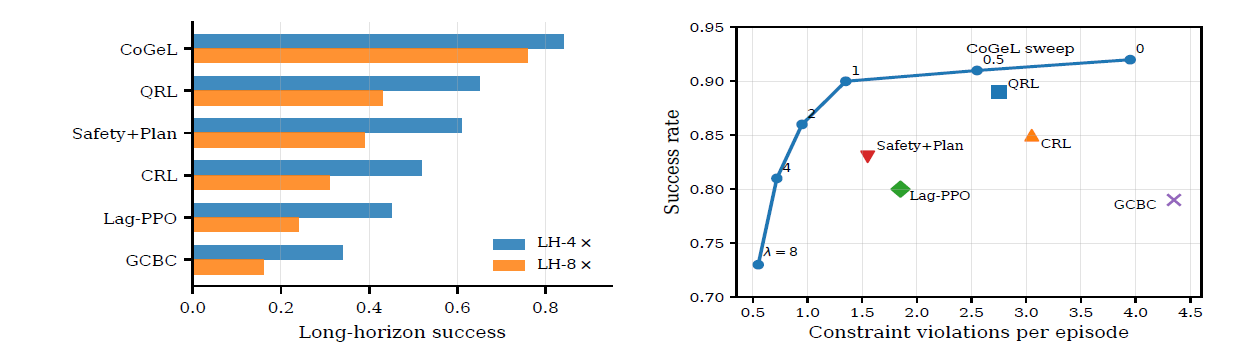
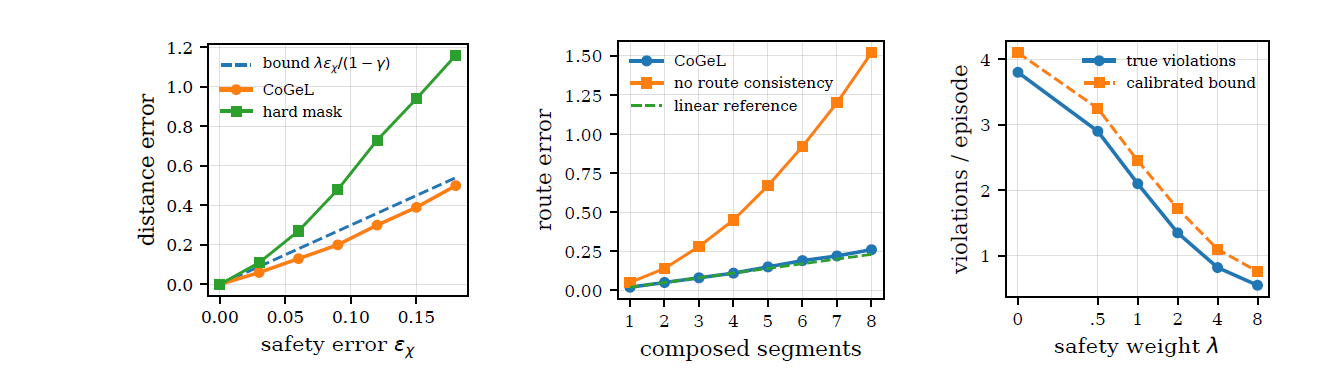
Many robot hazards are directional. Entering slippery terrain, climbing onto unstable debris, or approaching a narrow region may cost more than leaving it.
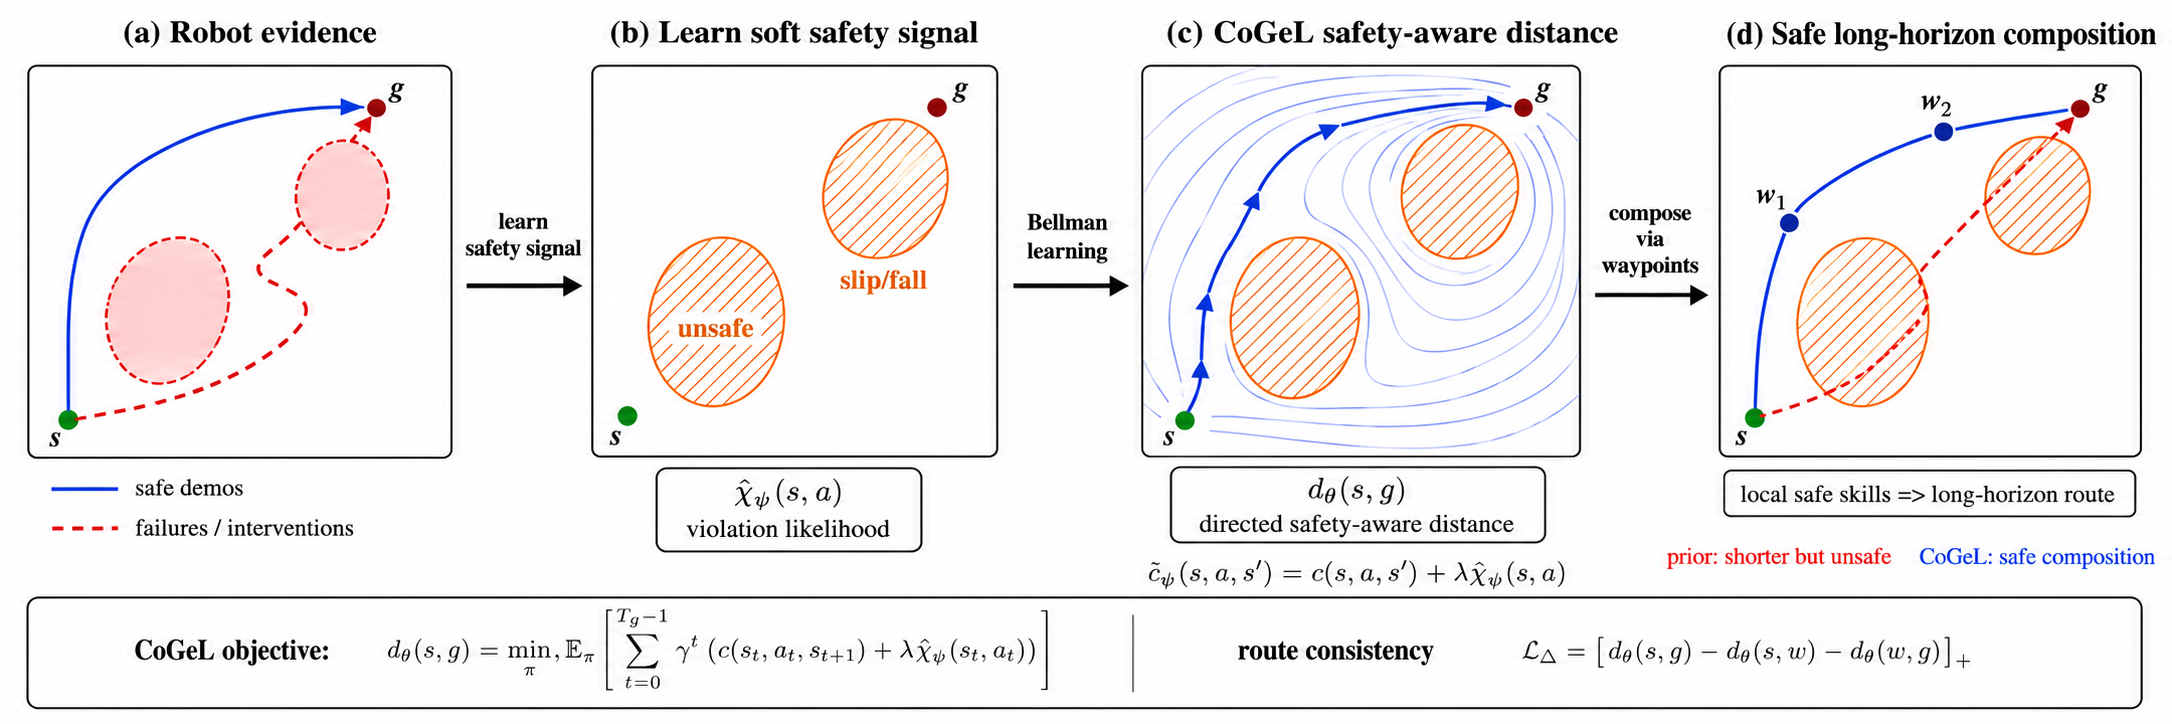
CoGeL therefore learns a directed distance:
\[
d^\star(s,g)
\neq
d^\star(g,s).
\]
A symmetric metric must assign the same value to both directions and therefore cannot represent this difference.